

Learn / Practice
Delayed MuJoCo feedback: can an old observation predict now?
EMBODIED-AI / EXPLORE · Engineering cases
Twenty-four paired traces compare delay, position noise and constant-velocity prediction, retaining incomplete recoveries.
What was published after this article?
The original conclusions and next-step proposals are retained. These published follow-ups do not imply that every limitation has been resolved.
KEEP EXPLORING
Related content
- Engineering cases
MuJoCo velocity estimation: smoother signals can mean worse control
54 actual simulation rollouts compare finite differences, EMA and an oracle reference across position noise and observation delay.
View count unavailable
On this page 4
Reproduce from a clean checkout · this article’s revision
Windows PowerShell with Python 3.12. Use a new directory, not a working copy with unsaved changes. Each article pins its own revision; the first article’s revision does not contain later experiments.
git clone https://github.com/VirtualSelect/hohoo-embodied-agent.git hohoo-embodied-agent-study
cd hohoo-embodied-agent-study
git checkout 831789c2a1efb4564c4cfabc2298e48e16ada879
python -m venv .venv
$py = '.\.venv\Scripts\python.exe'
& $py -m pip install -r requirements-lock.txt
& $py experiments/planar_reach/run.py --out outputs/my-run
& $py experiments/planar_reach/audit.py outputs/my-run
Expect raw trajectories, summaries and audit results. Use a new output directory to preserve earlier results; runners differ in how they handle existing directories. E8–E10 share one experiment runner. No model calls are made; run the numeric experiment first and use the article’s separate replay command for video.
Troubleshooting: a missing experiment directory usually means the wrong revision; import failures require checking the interpreter and environment. OpenGL errors concern rendering steps. On Linux/macOS use .venv/bin/python; those platforms have not been retested.
Inspect the pinned code ↗Pinned code · Raw evidence · Lab record
Stable empty-scene control and a feasible path still depend on feedback. This study removes the obstacle and changes only observations: delay 0/80ms, position noise 0/10mm, and held versus constant-velocity-predicted position. Seeds 7, 19 and 41 yield 24 traces.
Prediction reduces some overshoot, but every 80ms-delay case still fails the frozen completion criterion.
Capture, delivery and decision
A packet samples state at capture, becomes available after the configured delay, and is consumed at a 20ms control tick. The controller uses zero force before the first packet and cannot read current state to fill gaps. Noise changes reported position, not physical state.
Velocity is delayed simulator truth without added noise, an optimistic sensor assumption—not visual velocity estimation. Both controllers use that old velocity in the damping term.
predicted_position = captured_position
                   + captured_velocity × (now - capture_time)
The predictor does not estimate acceleration, update velocity or implement a Kalman filter. Changing force violates the constant-velocity approximation; delayed velocity feedback remains a separate problem.
Recorded completion
| Delay / noise | hold passes | predict passes |
|---|---|---|
| 0ms / none | 3/3 | 3/3 |
| 0ms / 10mm | 1/3 | 1/3 |
| 80ms / none | 0/3 | 0/3 |
| 80ms / 10mm | 0/3 | 0/3 |
No-noise seeds duplicate deterministic conditions, not independent random trials. Three noisy seeds are sensitivity examples, not a population estimate.
At 80ms without noise, peak overshoot drops from 210.7mm to 52.0mm, but final error changes from 2.79mm to 26.76mm. Neither remains within 15mm and below 40mm/s throughout the final 0.3 seconds. Selecting the overshoot metric alone would incorrectly suggest recovery.
Some zero-delay noisy failures end only 1.36mm or 0.30mm from the target. A favorable final frame cannot replace a sustained position-and-speed condition.
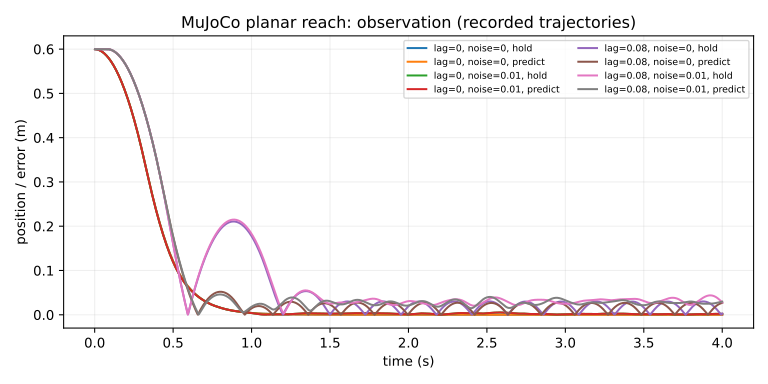
The figure shows seed seven only; all seeds are archived.
Recompute instead of trusting the controller
The auditor checks that capture times precede current time and evaluates completion from physical x/y/vx/vy, not estimated state. Otherwise an estimator could certify its own incorrect belief.
Exercise: inspect a small-final-error failure and find which tail-window sample violates which threshold. Reduce delay in a new output directory, retaining the original protocol and failures instead of moving thresholds afterward.
Acceleration models, velocity noise, filtering, lower gains or age-based stopping are candidates for new paired experiments. None is already validated here. This planar system and predictor establish no hardware-safety or articulated-arm guarantee.
Reproduce from a clean checkout
Python 3.12. The runner executes all three comparisons; each article discusses its own subset.
git clone https://github.com/VirtualSelect/hohoo-embodied-agent.git hohoo-embodied-agent-study
cd hohoo-embodied-agent-study
git checkout 831789c2a1efb4564c4cfabc2298e48e16ada879
python -m pip install -r requirements-lock.txt
python experiments/planar_reach/run.py --out outputs/my-run
python experiments/planar_reach/audit.py outputs/my-run
python experiments/planar_reach/plot.py outputs/my-run
Use a new output directory. Windows was exercised; Linux/macOS were not rerun. No model API or key is required. The source commit in the manifest precedes the evidence commit linked above; source hashes bind the executed files.
A note to your future selfBefore you move on, keep one thought of your own.
Your private reading note stays in this browser; it is never uploaded or published. Clearing browser data removes it, so export a copy to keep. This article’s translations share the same note.
Next published article:MuJoCo velocity estimation: smoother signals can mean worse control →
You are here
EXPLORE / Getting started with embodied AI
- ○ MuJoCo obstacle clearance: a point path is not a body path
- ○ Delayed MuJoCo feedback: can an old observation predict now?
- ○ MuJoCo velocity estimation: smoother signals can mean worse control
KEEP EXPLORING
Related content
- LAB / 038
Delayed MuJoCo feedback: can an old observation predict now?
Twenty-four paired traces compare delay, position noise and constant-velocity prediction, retaining incomplete recoveries.
- PROJECT / 003
Hohoo Embodied Experiments
Two MuJoCo teaching scenes—pick-and-place and planar force control—record contracts, tuning, clearance and delayed-feedback outcomes, including failures.
- Engineering cases
MuJoCo obstacle clearance: a point path is not a body path
Six contact trajectories compare direct, edge and clearance paths while separating geometry from controller tracking.
Which way next?
- MuJoCo obstacle clearance: a point path is not a body path →
Six contact trajectories compare direct, edge and clearance paths while separating geometry from controller tracking.
Based on article relationships and published same-topic content, not random recommendations.